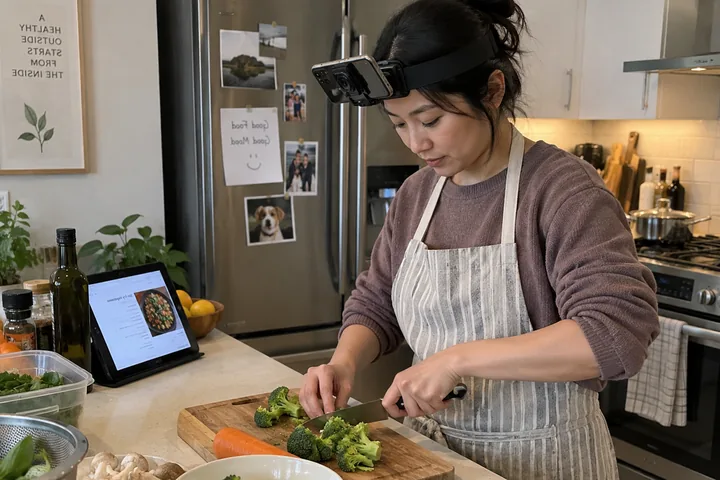
Household
Cooking, cleaning, folding clothes, organizing objects, appliance use and other daily activities.
 Egocentric Data Collection for Physical AI
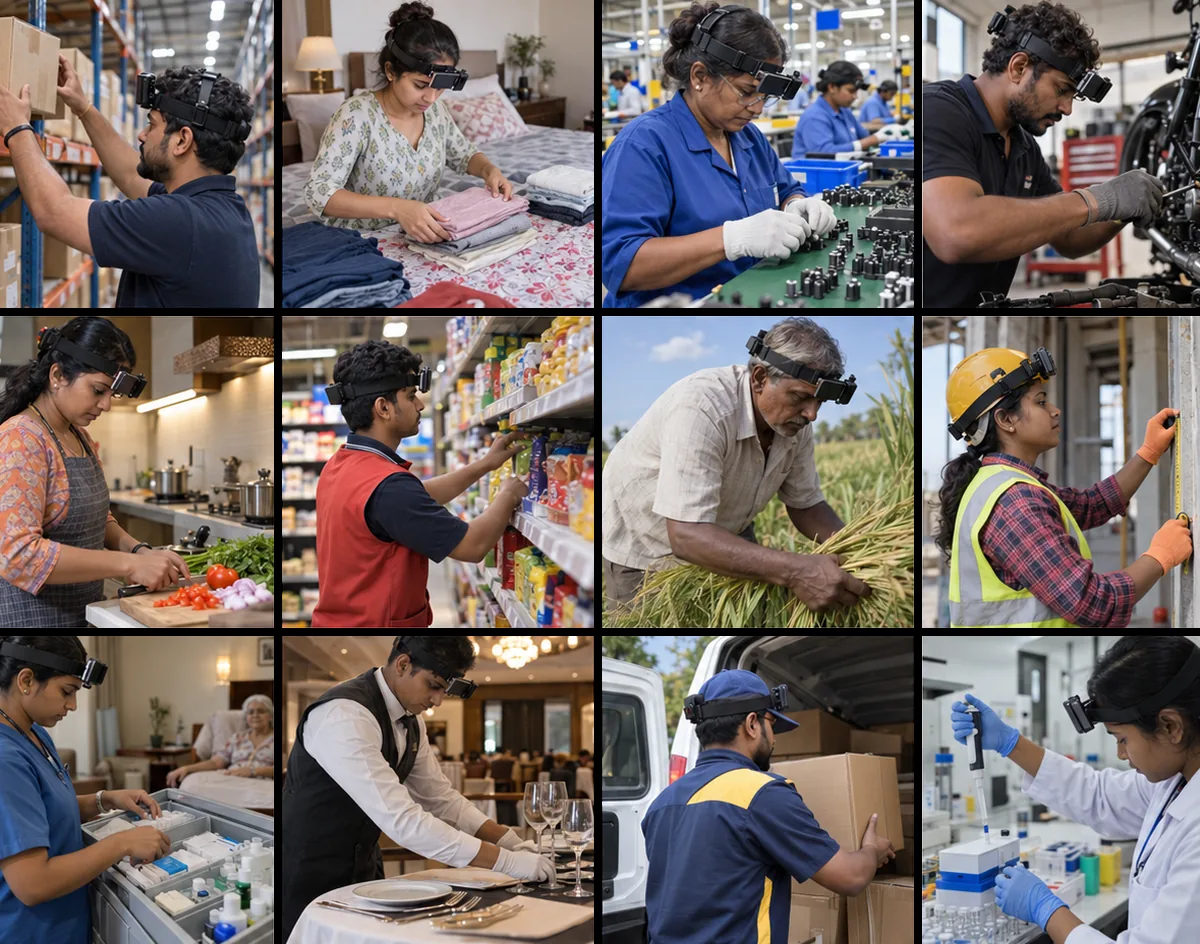
Sourcebae captures first-person video of people performing real tasks across homes, factories, warehouses, workshops, farms and commercial environments.
Built for robotics, VLA models, embodied AI and world models.

300K+
Trained experts & contributors

800+
New recording hours every week

99.2%
QA pass rate

12+
Real-world environment categories
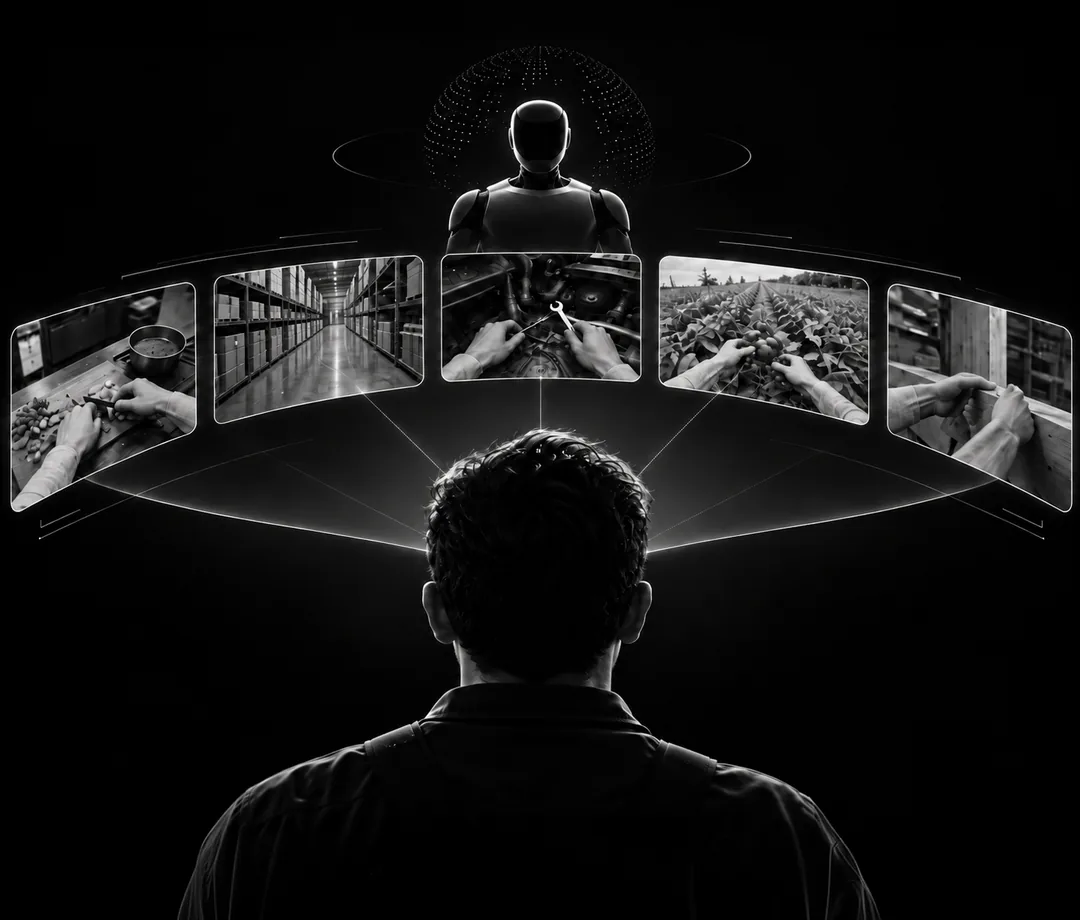
Robots cannot learn every physical task from internet data.
They need real demonstrations of people picking, placing, folding, assembling, repairing, sorting, cooking, cleaning and handling tools.
Sourcebae captures these actions from the
worker's point of view, giving AI models a clear view of:
We collect egocentric data across different industries and everyday environments.
Cooking, cleaning, folding clothes, organizing objects, appliance use and other daily activities.
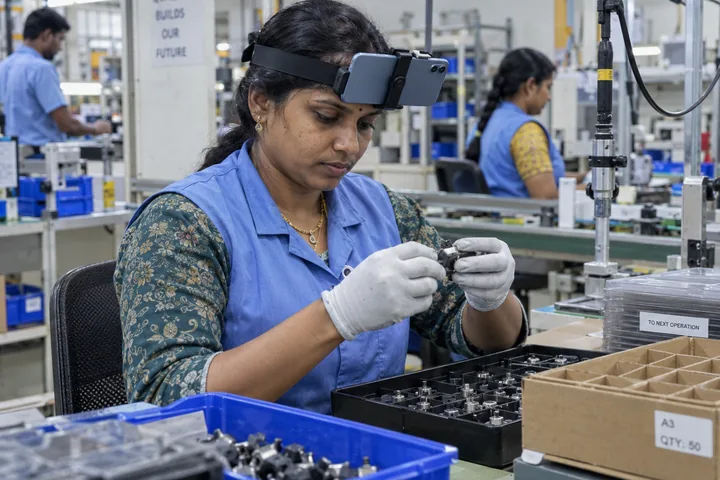
Assembly, inspection, machine operations, packaging, material handling and production tasks.
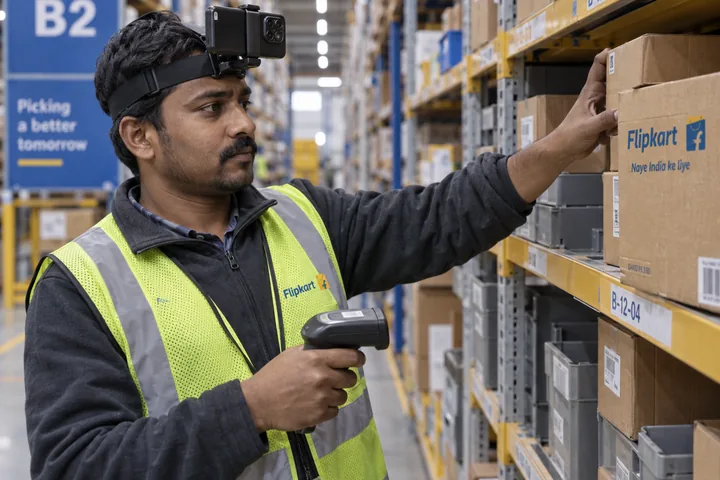
Picking, placing, packing, sorting, scanning, loading and shelf operations.
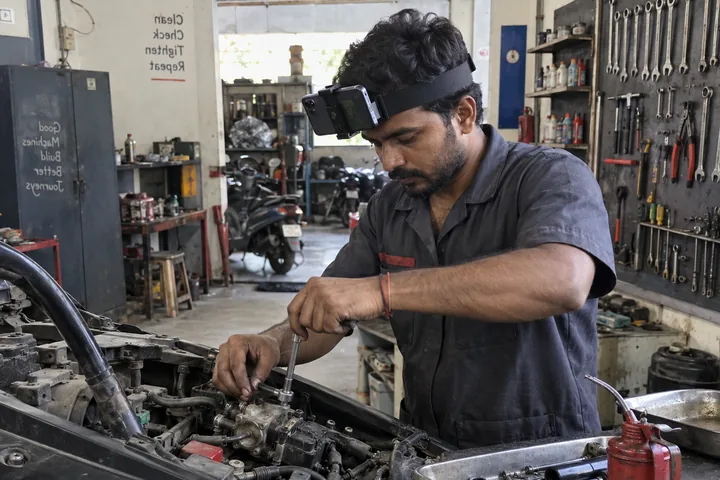
Mechanical repair, automotive work, equipment servicing and tool-based tasks.
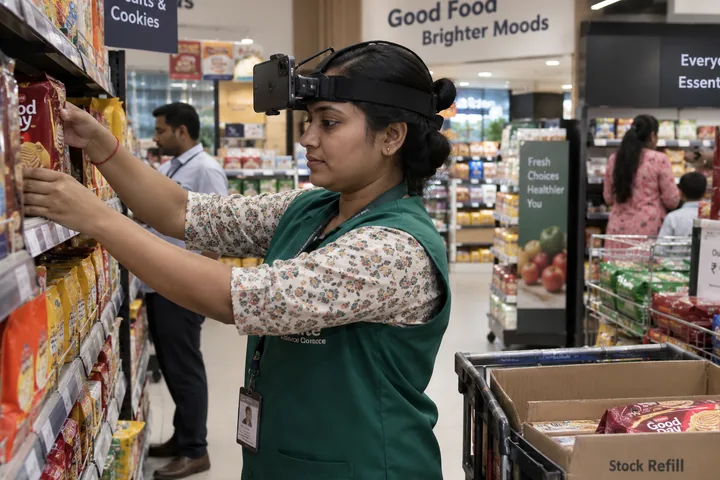
Retail stores, commercial kitchens, laundries, food processing and other workplaces.
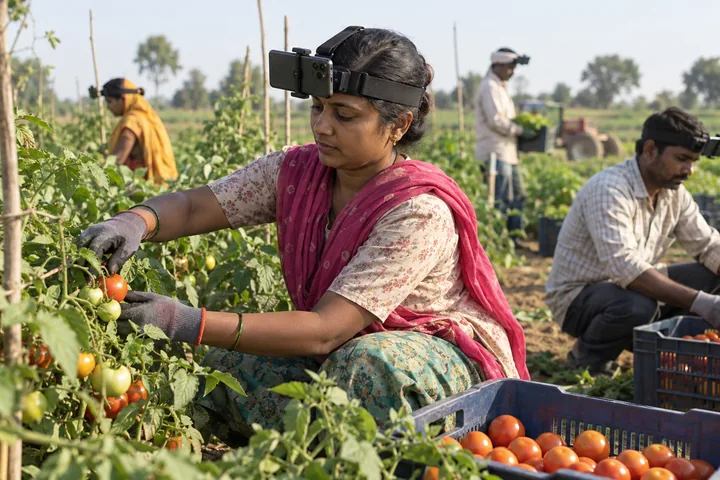
Harvesting, sorting, grading, tool use, crop handling and outdoor work.
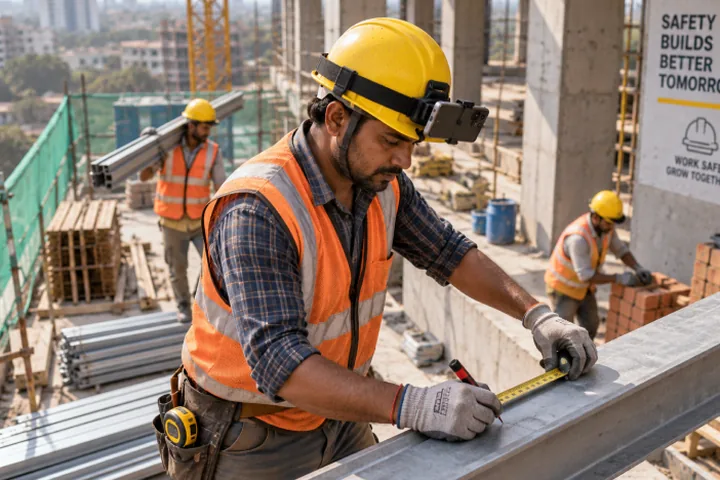
Material handling, measuring, drilling, fastening, installation, inspection, site preparation and equipment operation.
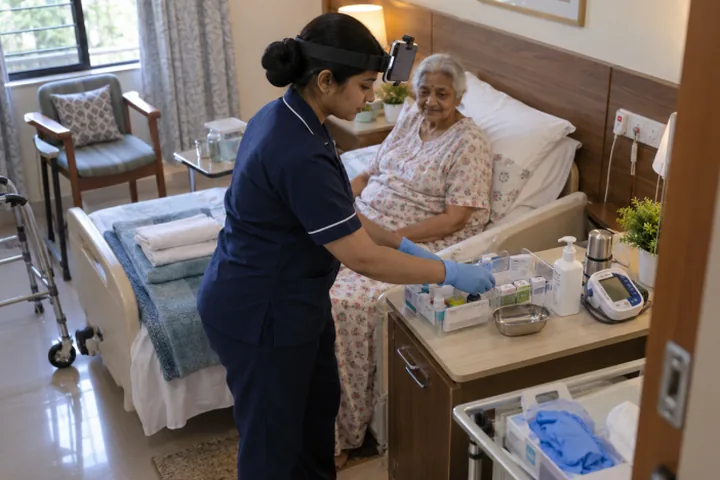
Patient support workflows, medical equipment handling, room preparation, supply organization and assisted-living activities.
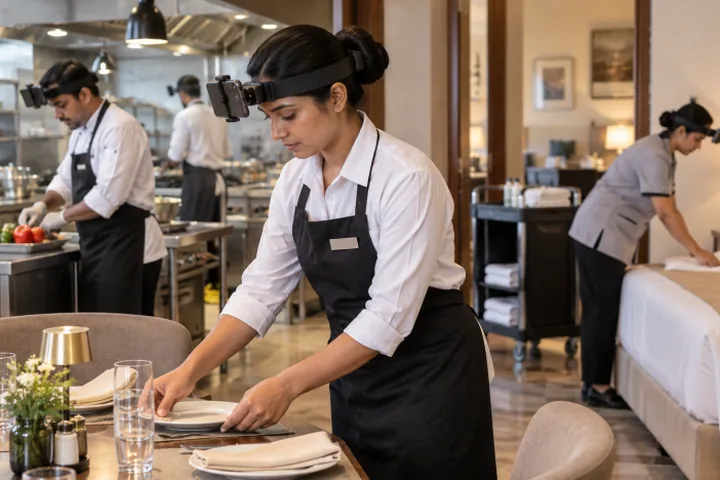
Table setup, food preparation, kitchen operations, cleaning, room service, housekeeping and guest-service workflows.
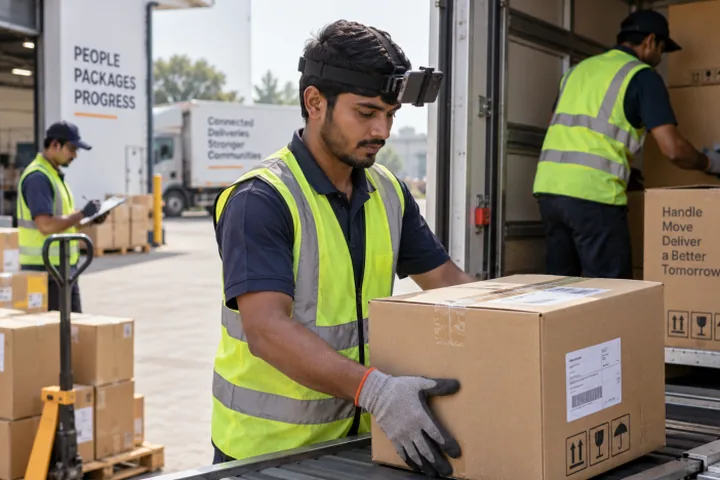
Package handling, vehicle loading, delivery preparation, route-based tasks, cargo organization and transportation workflows.
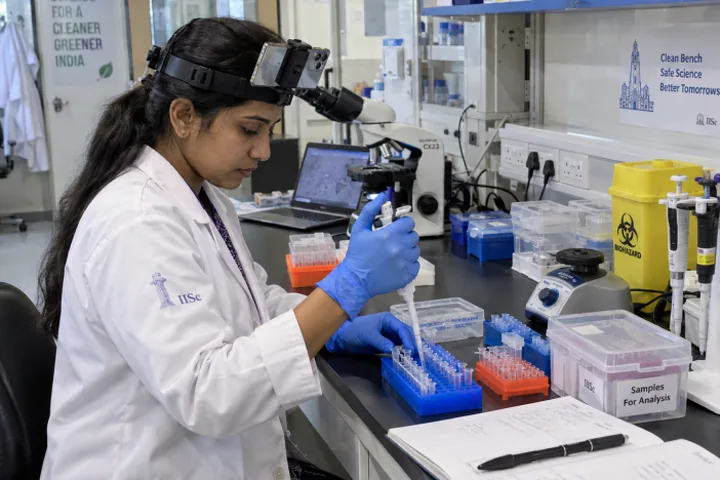
Sample handling, equipment operation, inspection, preparation workflows, controlled experiments and laboratory organization.
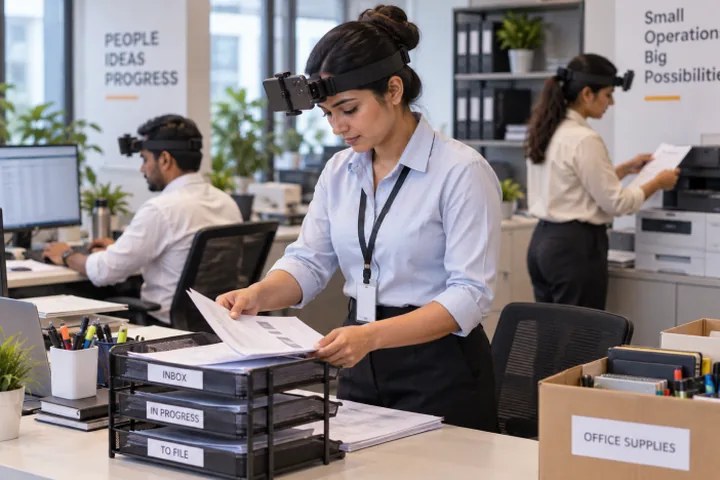
Document handling, desk organization, equipment setup, mailroom workflows, supply management and administrative tasks.
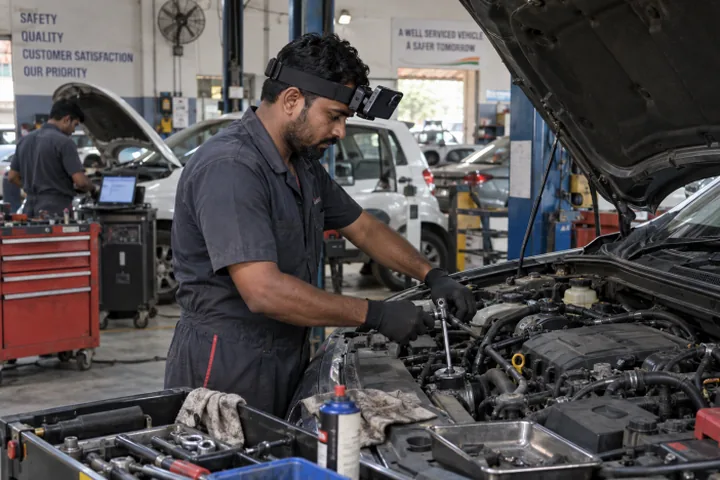
Vehicle inspection, maintenance, repair, part handling, assembly, cleaning and service-center workflows.
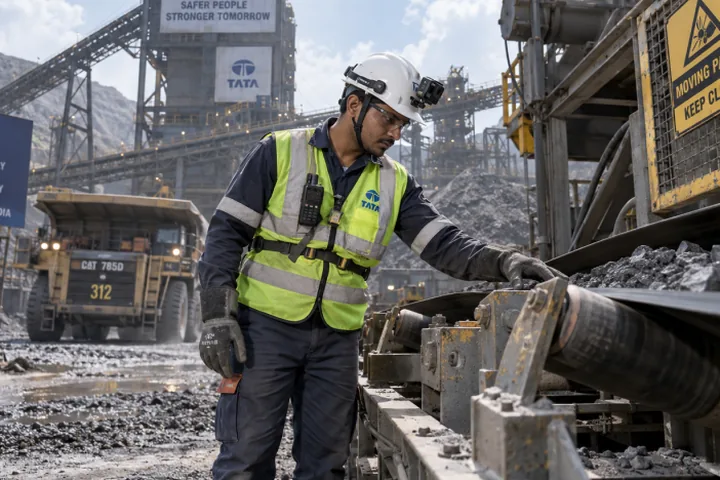
Equipment operation, inspection, material handling, maintenance, safety procedures and industrial workflows.
Not every task should be recorded by a random participant.
Sourcebae can match contributors based on the skill your model needs to learn.


Better demonstrations start with the right humans
Your dataset can include the signals your model needs

High-quality first-person task recordings

Natural task narration and spoken instructions where required

Hand, body and motion data based on the capture setup

Additional sensor signals for projects that require spatial and motion context

Task steps, actions, object interactions, success and failure events

Task, environment, contributor, device and recording information
One managed workflow from task design and participant sourcing to capture, QA, annotation and structured delivery.
Tell us what your model needs to learn. We define the tasks, environments, contributors, devices and quality requirements.
We recruit the right people and secure the required environments.
We run a small collection first so your team can review the data.
Contributors perform real tasks using the approved recording setup.
Every batch is checked against the agreed quality standards and annotation requirements.
Approved data is organized and delivered in your required structure and format.
Our egocentric datasets can support

Connect visual scenes, instructions and physical actions.

Train models across diverse tasks, objects and environments.

Teach robots using real human demonstrations.

Learn how humans handle objects, tools and materials.

Capture how people interact with and change physical environments.

Test how models perform across new tasks and real-world conditions.
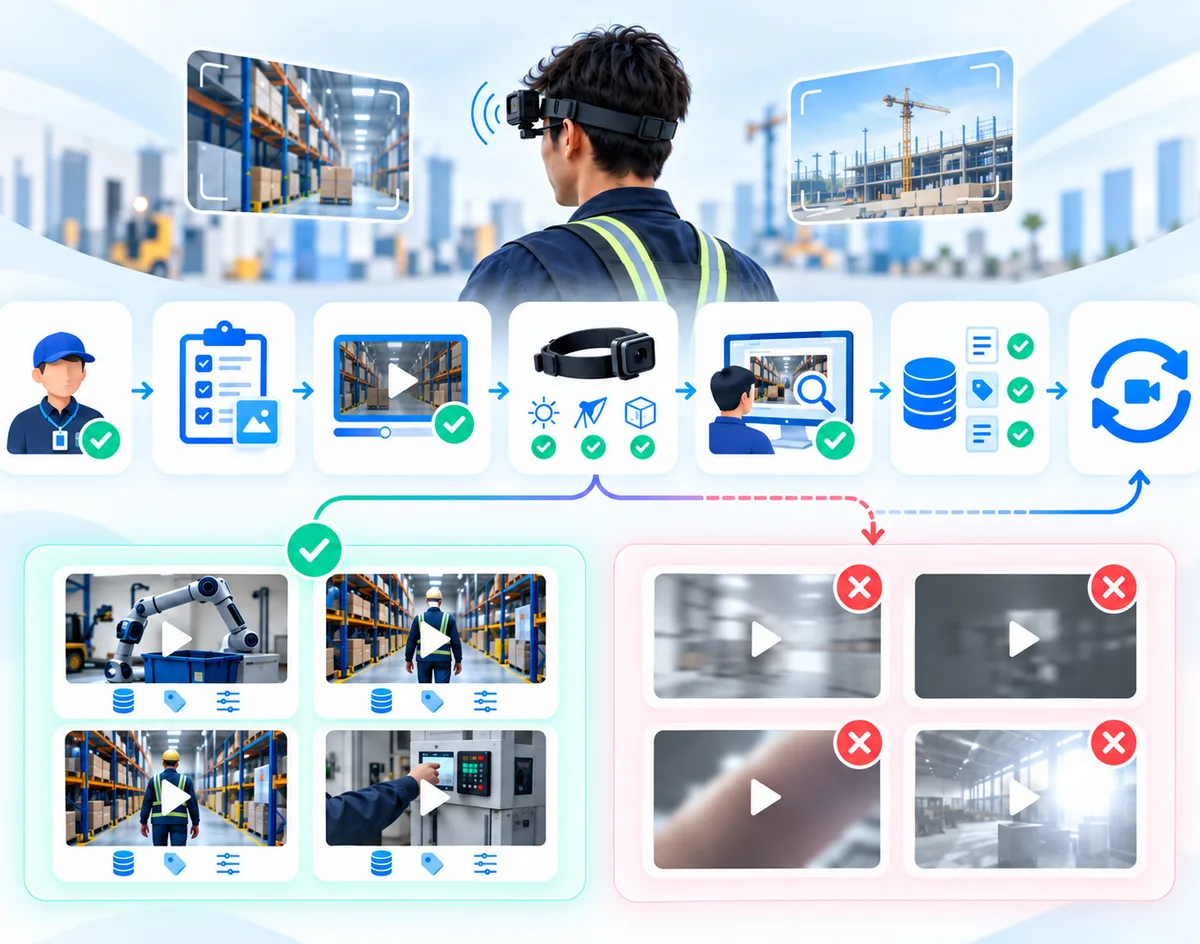
Good training data is not just about collecting more hours.
Sourcebae builds quality checks into the complete collection process.
 Contributor onboardingTask-specific instructionsSample recording approvalCamera and environment checksHuman QAMetadata validationRecapture when required
The result: Cleaner data and fewer unusable hours.
Each project has a project-specific capture checklist covering camera position, lighting, task completion, hand/object visibility, recording continuity and metadata completeness.

Access trained contributors and domain experts for both everyday and specialized tasks.

Collect across homes, factories, warehouses, workshops, commercial spaces and outdoor environments.

Configure cameras, sensors, narration and metadata around your model requirements.

Contributor sourcing, onboarding, capture, QA, annotation and delivery managed by one team.

Validate the data first. Scale production after your team approves the output.
Egocentric data collection records tasks from the first-person point of view of the person performing them. It helps AI models understand hands, objects, tools and actions from a human perspective.

Tell us what your robot or Physical AI model needs to learn. We'll help define the people, tasks, environments and capture setup needed to build the dataset.
©Sourcebae 2026 | All Rights Reserved